> For the complete documentation index, see [llms.txt](https://apphp.gitbook.io/artificial-intelligence-with-php/llms.txt). Markdown versions of documentation pages are available by appending `.md` to page URLs; this page is available as [Markdown](https://apphp.gitbook.io/artificial-intelligence-with-php/machine-learning/mathematics-for-ml/linear-algebra/linear-transformations/introduction.md).
# Introduction
### **1. Understanding Linear Mappings Between Vector Spaces**
#### **Definition**
A **linear transformation** is a mapping between two vector spaces that preserves vector addition and scalar multiplication. In simple terms, linear transformations ensure that the structure of a vector space is maintained during the mapping.
Mathematically, a function $$T:V→W$$ between two vector spaces $$V$$ and $$W$$ (over the same field, such as real numbers $$\mathbb{R}$$) that satisfies two main properties::
1. **Additivity** (preserves vector addition):\
\
$$T(u + v) = T(u) + T(v), \quad \forall u, v \in V$$.\\
2. **Homogeneity** (preserves scalar multiplication):\
\
$$T(c u) = c T(u), \quad \forall c \in \mathbb{R}, u \in V.$$
These two properties ensure that a linear transformation maintains the "linear structure" of a vector space, such as straight lines, scalar multiples, and sums.
#### **Matrix Representation of Linear Transformations**
Any linear transformation $$T: \mathbb{R}^n \to \mathbb{R}^m$$ can be represented as a matrix $$A \in \mathbb{R}^{m \times n}$$:
$$T(x) = Ax,$$
where $$\mathbf{x} \in \mathbb{R}^n$$ n is the input vector, and $$𝐴$$ is the transformation matrix.
***
#### **Example 1:**
If $$T: \mathbb{R}^2 \to \mathbb{R}^2$$ is defined as $$T\left( \begin{bmatrix} x \ y \end{bmatrix} \right) = \begin{bmatrix} 2x \ 3y \end{bmatrix}$$
it is a linear transformation because it satisfies both vector addition and scalar multiplication.
#### **Example 2:**
(Simple Scaling Transformation)
If $$T: \mathbb{R}^2 \to \mathbb{R}^2$$ scales a vector $$\mathbf{x} = \begin{bmatrix} x \ y \end{bmatrix}$$, then: $$T\left( \begin{bmatrix} x \ y \end{bmatrix} \right) = \begin{bmatrix} 2x \ 3y \end{bmatrix}$$
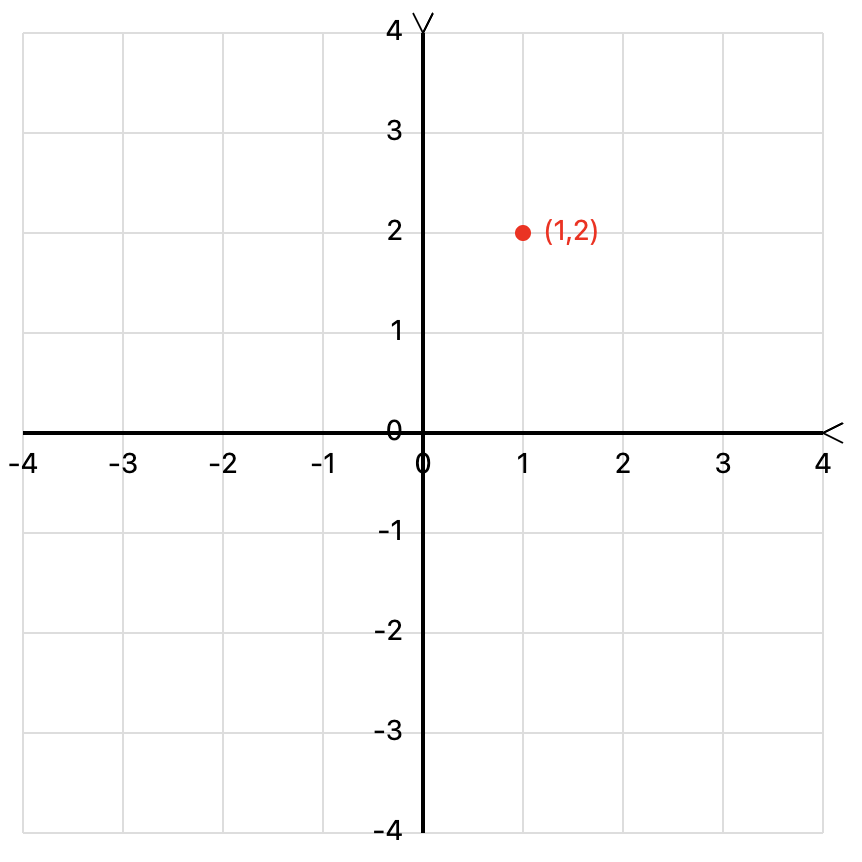
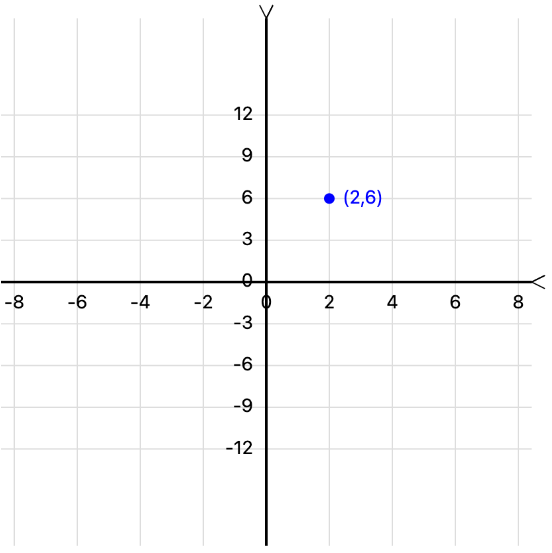
For $$\mathbf{x} = \begin{bmatrix} 1 \ 2 \end{bmatrix}$$, the output is: $$T\left( \begin{bmatrix} 1 \ 2 \end{bmatrix} \right) = \begin{bmatrix} 2 \cdot 1 \ 3 \cdot 2 \end{bmatrix} = \begin{bmatrix} 2 \ 6 \end{bmatrix}$$
**Visualization of a Scaling Transformation**
Scaling transforms a square grid, stretching it vertically and horizontally:
| Original Grid | Scaled Grid (2x, 3y) |
|---|
 |  |
Step by step explanation
1. Original Grid:
* A standard coordinate system with equal spacing
* The point (1,2) marked in red
* Grid lines for reference
2. Scaled Grid:
* The same coordinate system after applying the transformation
* The transformed point (2,6) marked in blue
* Grid lines showing the scaling effect (2x horizontal, 3y vertical)
* Reference axes remaining in original position
You can clearly see how the transformation stretches the grid, with:
* Horizontal spacing doubled (2x scaling in x-direction)
* Vertical spacing tripled (3y scaling in y-direction)
The example point moves from (1,2) to (2,6), demonstrating how the transformation affects individual points in the space.
\
**Example 3:**
Let $$T: \mathbb{R}^2 \to \mathbb{R}^2$$ be defined as: $$T\left( \begin{bmatrix} x \ y \end{bmatrix} \right) = \begin{bmatrix} 3x + 2y \ -x + 4y \end{bmatrix}.$$
This transformation can be expressed using a matrix: $$A = \begin{bmatrix} 3 & 2 \ -1 & 4 \end{bmatrix}.$$
Given , the transformation is:
$$T(x) = Ax = \begin{bmatrix} 3 & 2 \ -1 & 4 \end{bmatrix} \begin{bmatrix} 1 \ 2 \end{bmatrix}$$
Perform the multiplication:
$$T(x) = \begin{bmatrix} 3(1) + 2(2) \ -1(1) + 4(2) \end{bmatrix} = \begin{bmatrix} 7 \ 7 \end{bmatrix}.$$
#### **Visualization of the Transformation**
| Original Vector | Transformed Vector |
|---|
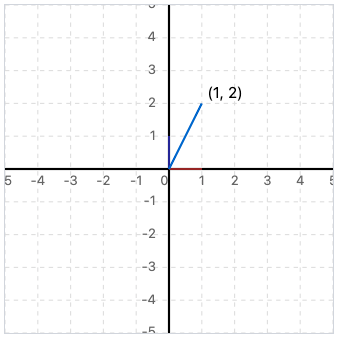 | 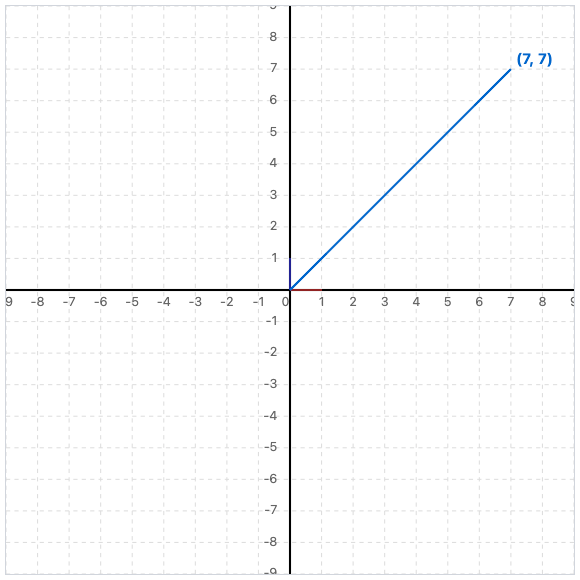 |
The original grid is distorted based on the transformation matrix $$A$$, stretching and rotating the space.
Step by step explanation
Let's start with the given transformation matrix A and walk through how it transforms \[1, 2] to \[7, 7].
1. The transformation matrix A is:
```
A = [3 2]
[-1 4]
```
2. When we multiply matrix A by vector \[1, 2], we get:
```
[3 2] [1] = [3(1) + 2(2)]
[-1 4] [2] [-1(1) + 4(2)]
```
3. Let's calculate each component:
* First component (x-coordinate):
* 3(1) + 2(2)
* \= 3 + 4
* \= 7
* Second component (y-coordinate):
* -1(1) + 4(2)
* \= -1 + 8
* \= 7
4. Therefore:
```
A[1] = [7]
[2] [7]
```
This shows how the linear transformation A maps the vector \[1, 2] to \[7, 7]. The transformation stretches and rotates the original vector in such a way that the resulting vector has coordinates \[7, 7].
***
### **2. Mathematical Properties of Linear Transformations**
A linear transformation $$T: \mathbb{R}^n \to \mathbb{R}^m$$ has the following properties:
1. **Zero Vector Mapping**:\
The zero vector in $$V$$ always maps to the zero vector in $$W$$:\
\
$$T(0) = 0$$\\
2. **Preservation of Linear Combinations**:\
For vectors $$u, v \in V$$ and scalars $$a, b \in \mathbb{R}$$:\
\
$$T(au + bv) = aT(u) + bT(v)$$\\
3. **Kernel (Null Space)**:\
The set of all vectors that map to the zero vector:\
\
$$\text{Ker}(T) = { x \in V : T(x) = 0 }$$\\
4. **Image (Range)**:\
The set of all vectors in $$W$$ that are outputs of $$T$$:\
\
$$\text{Im}(T) = { T(x) : x \in V }$$
### **3. Geometric Interpretation**
* **Scaling** stretches or compresses vectors.
* **Rotation** changes the direction of vectors.
* **Reflection** mirrors vectors across an axis.
#### **Visualization**
Below are visualizations of common transformations:
| Scaling Transformation | Rotation Transformation | Reflection Transformation |
|---|
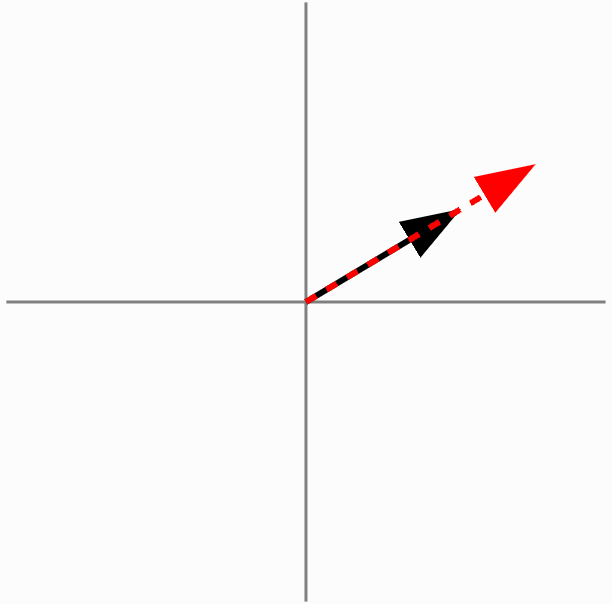 | 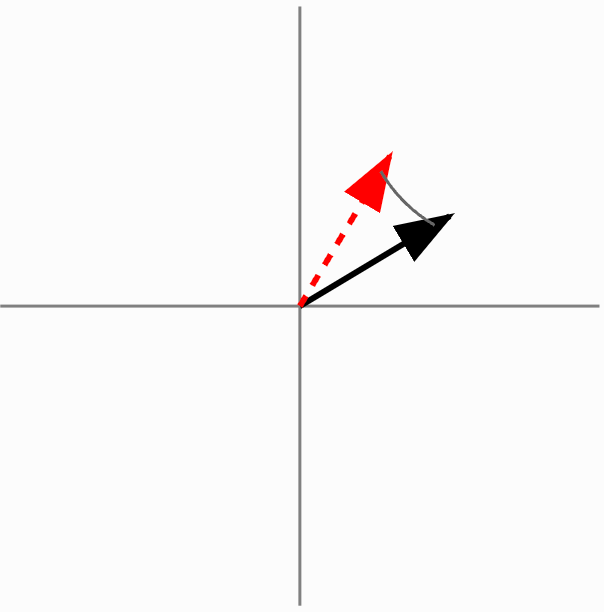 | 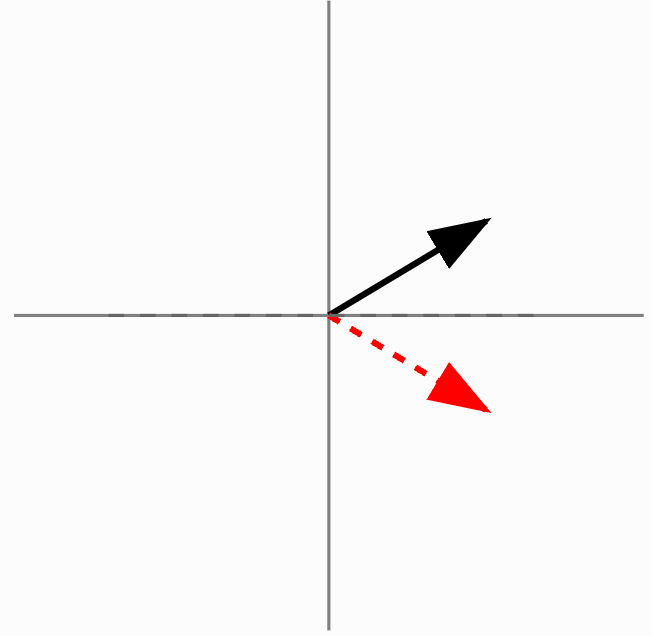 |
### **4. Application of Matrices in Transforming Data**
Linear transformations can be efficiently represented as **matrix multiplications**. For a transformation $$T$$ represented by matrix $$A$$:
$$T(x) = Ax$$
***
#### **Example 1:**
The rotation matrix rotates vectors by an angle $$\theta$$:
$$A = \begin{bmatrix} \cos\theta & -\sin\theta \ \sin\theta & \cos\theta \end{bmatrix}$$
For $$\theta = 90^\circ$$:
$$A = \begin{bmatrix} 0 & -1 \ 1 & 0 \end{bmatrix}$$
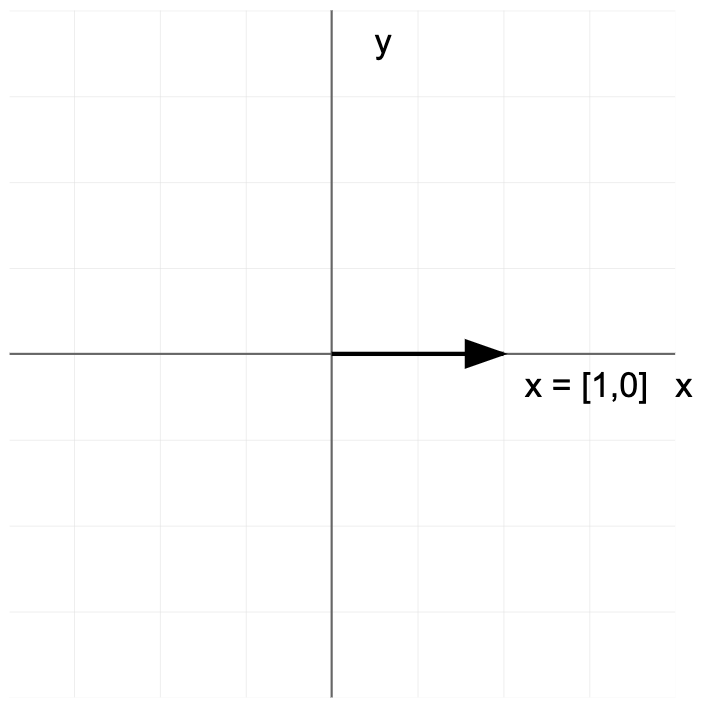
Rotating $$x = \begin{bmatrix} 1 \ 0 \end{bmatrix}$$:
$$Ax = \begin{bmatrix} 0 & -1 \ 1 & 0 \end{bmatrix} \begin{bmatrix} 1 \ 0 \end{bmatrix} = \begin{bmatrix} 0 \ 1 \end{bmatrix}$$
| Original Grid | Rotated Grid (90°) |
|---|
 | 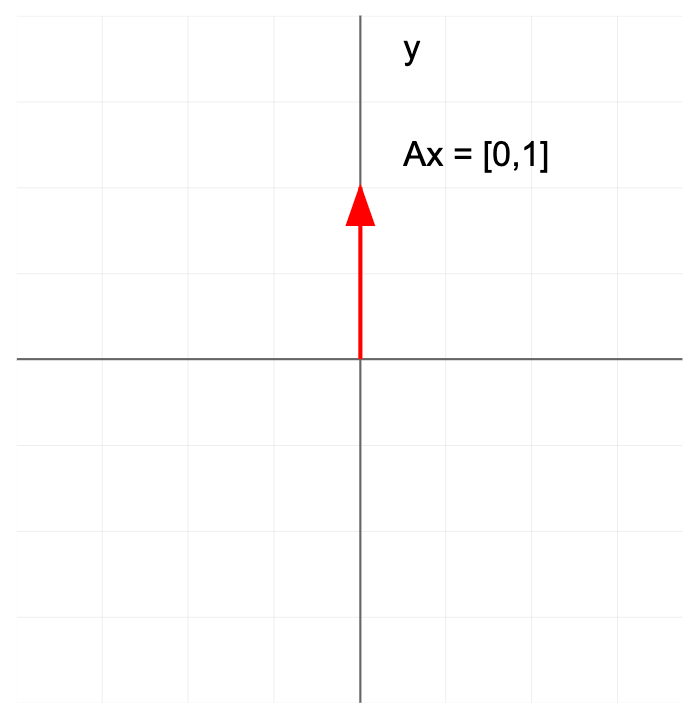 |